Principal Investigators
Gioele ZardiniLead PI
Massachusetts Institute of Technology
Lead PI, SCHEMA · Rudge (1948) and Nancy Allen Assistant Professor, MIT
Gioele Zardini is the Rudge (1948) and Nancy Allen Assistant Professor at MIT, a PI in the Laboratory for Information and Decision Systems (LIDS) and the Department of Civil and Environmental Engineering (CEE), and affiliate faculty with the Institute for Data, Systems and Society (IDSS). His research develops efficient computational tools and algorithmic approaches to formulate and solve complex, interconnected system-design and autonomous decision-making problems, drawing on optimization, control theory, game theory, and applied category theory.
Aaron D. Ames
California Institute of Technology
Co-PI · Bren Professor, California Institute of Technology
Aaron D. Ames is the Bren Professor of Mechanical and Civil Engineering and Control and Dynamical Systems at Caltech, where he leads the AMBER Lab. His research develops safety-critical control for robotic systems, with an emphasis on formal guarantees for dynamic and legged locomotion.
Ali Jadbabaie
Massachusetts Institute of Technology
Co-PI · JR East Professor of Engineering, MIT
Ali Jadbabaie is the JR East Professor of Engineering at MIT, with appointments in the Department of Civil and Environmental Engineering, LIDS, and IDSS. His research spans network science, optimization, machine learning, and the analysis of large-scale dynamical and multi-agent systems.
Nikolai Matni
University of Pennsylvania
Co-PI · Associate Professor, University of Pennsylvania
Nikolai Matni is an Associate Professor in the Department of Electrical and Systems Engineering at the University of Pennsylvania. His research lies at the intersection of learning, optimization, and control, with a focus on the theoretical foundations of learning for control and layered control architectures.
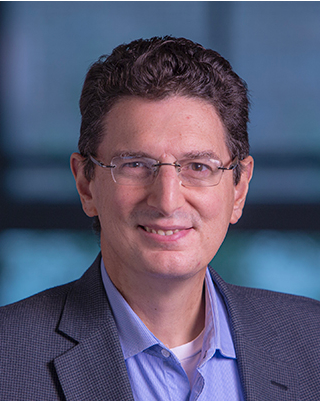
George J. Pappas
University of Pennsylvania
Co-PI · UPS Foundation Professor, University of Pennsylvania
George J. Pappas is the UPS Foundation Professor of Transportation in the Department of Electrical and Systems Engineering at the University of Pennsylvania. His research spans control theory, formal methods, and autonomy, including safety and verification for cyber-physical and learning-enabled systems.
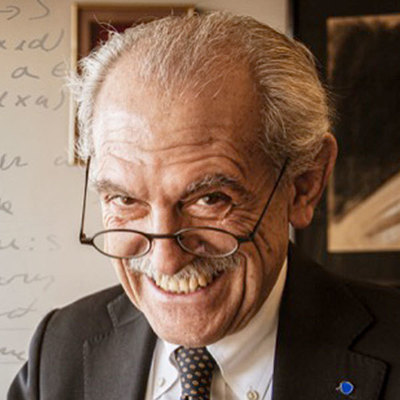
Alberto Sangiovanni-Vincentelli
University of California, Berkeley
Co-PI · The Edgar L. and Harold H. Buttner Chair, UC Berkeley
Alberto Sangiovanni-Vincentelli is a Professor in the Department of Electrical Engineering and Computer Sciences at UC Berkeley. A pioneer of contract-based and platform-based design, his work spans formal methods, design methodologies, and cyber-physical systems.
AFOSR / AFRL Program Team
Warren Adams
Air Force Office of Scientific Research (AFOSR)
Program Officer, Optimization and Discrete Mathematics · Air Force Office of Scientific Research (AFOSR)
Dr. Warren Adams manages AFOSR’s Mathematical Optimization program, overseeing research in optimization and discrete mathematics.
Jared Culbertson
Air Force Research Laboratory (AFRL)
Research Mathematician, Autonomous Capabilities Team (ACT3) · Air Force Research Laboratory (AFRL)
Dr. Jared Culbertson is a research mathematician with AFRL’s Autonomous Capabilities Team (ACT3). His research spans applied category theory, hybrid systems, and reinforcement learning for autonomous air and space systems.
Matt Klawonn
Air Force Research Laboratory (AFRL)
Lead, AFRL Technical Directorates · Air Force Research Laboratory (AFRL)
Dr. Matt Klawonn leads the AFRL Technical Directorates’ engagement with the SCHEMA Center of Excellence.
Frederick Leve
Air Force Office of Scientific Research (AFOSR)
Program Officer, Dynamical Systems and Control Theory · Air Force Office of Scientific Research (AFOSR)
Dr. Frederick Leve manages AFOSR’s Dynamical Systems and Control Theory portfolio. He previously served as a research aerospace engineer in AFRL’s Space Vehicles Directorate, leading attitude dynamics and controls research, and holds a PhD from the University of Florida.
Scott Nivison
Air Force Research Laboratory (AFRL)
AI and Decision-Making Autonomy Technical Lead, Munitions Directorate · Air Force Research Laboratory (AFRL)
Dr. Scott Nivison leads AI and decision-making autonomy research in AFRL’s Autonomy, Navigation, and Control Branch. His work focuses on multi-agent reinforcement learning, adaptive control, and safe autonomy for heterogeneous swarms.
Postdoctoral Scholars
Students
Alumni
Charis Stamouli
Former PhD Student, University of Pennsylvania
Currently: Postdoctoral Researcher, ETH Zürich